Skip to content
Loading Khalifa Shuaib's portfolio

Work

Selected work

Five machines in five sectors, each taken from the first sketch to working hardware. Best first. Every project lists the problem, my role and the result. Open the breakdown for the detail.

Robotics · 2026

01 / 05

Industrial robotics, built at home

ARCTOS six-axis robot arm

A six-axis robot arm I printed, assembled, wired and brought up to joystick-controlled operation from the open-source ARCTOS design.

Role
Solo build
Result
A working 6-DoF arm with roughly 600 mm reach, verified axis by axis and running joystick-controlled pick, rotate and grip operations.

6

degrees of freedom

600 mm

design reach

2 kg

rated payload

The breakdown

ProblemIndustrial arms cost more than most labs in Nigeria can justify, yet they're the core of modern manufacturing. I wanted my own platform to learn gear trains, kinematics and motion control on real hardware.

What I builtI printed and assembled every structural part, built the gearboxes, wired the stepper drives and controller, then calibrated each axis and the gripper before running full teleoperated motions.

Arm design by ARCTOS Robotics (open source). Fabrication, assembly, wiring, calibration and operation by me.
Healthtech · 2025

02 / 05

Retinal imaging on a smartphone

Lumina handheld ophthalmoscope

A smartphone-mounted fundus camera I designed in SolidWorks, rendered and fabricated, so clinics can screen for diabetic retinopathy without a desktop fundus camera.

Role
CTO, hardware lead, FundusAI
Result
Optical axis held within ±2 mm despite FDM shrinkage, over 50% illumination uniformity and 15% better peripheral clarity. Used in community screening outreach.

±2 mm

optical alignment

>50%

illumination uniformity

+15%

peripheral clarity

The breakdown

ProblemDiabetic retinopathy is preventable blindness, but screening needs fundus cameras that most clinics outside major cities don't have.

What I builtI designed the optics housing, focusing mechanism and illumination, then iterated the printed parts. That meant tolerance analysis on the housing and helical gear focus drive, plus ray-traced LED diffuser geometry. It tied together optics, computer vision, a mobile app and embedded control.

Agritech · 2024 – 2026

03 / 05

Fish farms you can run from your phone

Future Fish aquaculture automation

A solar-powered, modular IoT system that monitors water quality and feeds catfish automatically, with a mobile app and an auger feeder I designed from scratch.

Role
Co-founder & technical lead, Future Fish AgroTech
Result
About 12% lower feed conversion ratio in AI-scheduled ponds across an 8-pond, two-cycle trial, with farms running in Abuja, Lagos, Oyo and Kaduna. Patent application filed.

−12%

feed conversion ratio

8

pond controlled trial

4

states with farms

The breakdown

ProblemSmallholder catfish farmers feed by habit and check water by hand. Feed is their biggest cost, and fixed manual schedules waste it.

What I builtConsumer-ready ESP32 firmware with OTA updates, automatic Wi-Fi setup and plug-in sensor detection. Also an MQTT architecture that tolerates patchy connectivity, a solar-to-mains power switchover and a companion app. I designed the auger feeder and calibrated its flow rate across a range of pellet sizes.

Delivered with the National Agricultural Development Fund as implementation partner.

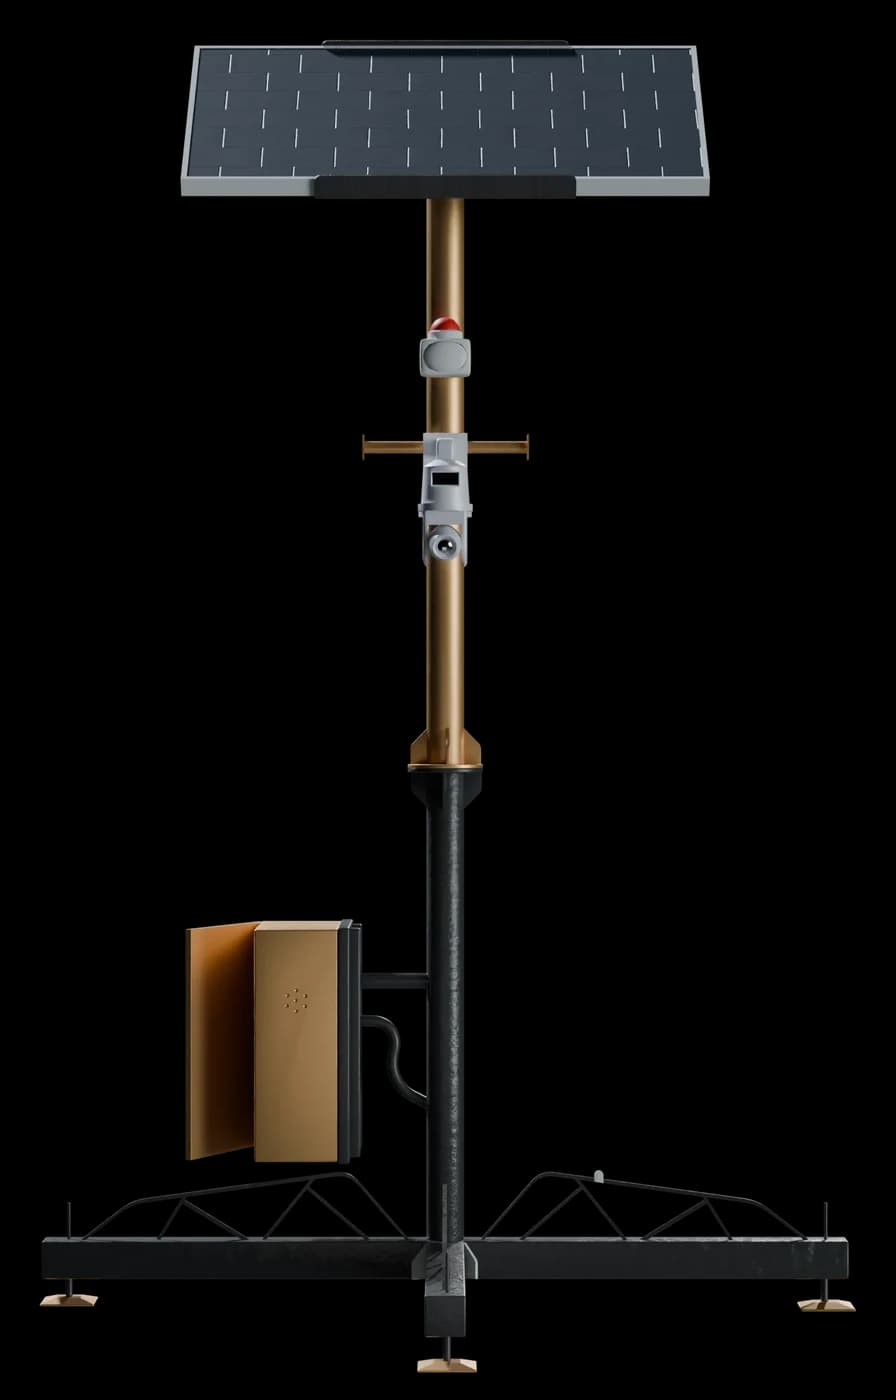
Terra Industries' Kallon sentry tower: a solar panel on a mast carrying PTZ cameras, with a battery enclosure on a tripod base
Image © Terra IndustriesRange 3 km · 360° PTZ

Defence · 2026

04 / 05

Autonomous perimeter security

Kallon sentry tower

Control architecture for Terra's solar-powered AI sentry tower, which protects critical infrastructure such as mines and pipelines across Africa.

Role
Mechatronics engineer, Terra Industries
Result
Part of a product line deployed commercially, including a fleet of 20 sentry towers protecting lithium mining sites in Nigeria.

3 km

detection range

360°

PTZ coverage

24/7

solar powered

The breakdown

ProblemCritical sites in remote areas need constant surveillance where grid power is unreliable and security response is slow.

What I builtI redesigned the tower's control architecture and the software services that run it. I also designed and printed mechanical parts and built custom PCBs for Terra's drone, UGV and tower platforms.

Product specifications from Terra Industries' public materials. Details of my work are kept high level for confidentiality.

Fintech · 2024 – 2025

05 / 05

Making keke finance measurable

Rickshaw monitoring & yield modelling

IoT trackers for keke (tricycle taxi) fleets that log every trip and only enable the vehicle once payment is verified, turning usage data into yield projections for asset financiers.

Role
CTO, Trykey Protocol
Result
First fleet deployment live. I cut edge-to-dashboard latency by 50% by reworking the real-time data pipeline.

−50%

pipeline latency

9

engineers led

1st

fleet deployment

The breakdown

ProblemFinanciers who lease out kekes can't see how their vehicles are used, so revenue leaks and lending decisions are guesswork.

What I builtI led a 9-engineer hardware team to design trackers that report location, distance, routes and passenger counts to a live dashboard. They're tied to a blockchain-backed payment check that controls vehicle access, with utilisation models turning the data into projected yield.

Earlier work

  • Space · 2021

    Design engineer

    CubeSat structure & deployables

    I led the design and simulation of a CubeSat, including its deployable solar array and structural frame.

    ResultComplete satellite system model and component specifications.

  • Space · 2021

    Project lead

    Rocker-bogie rover

    A six-wheel rover with a 3-DoF passive suspension and differential tie-rod that keeps every wheel on the ground.

    ResultSimulated stable operation on 45° inclines.

Third-party designs, logos and product specifications are credited on each project and on the credits page.