About
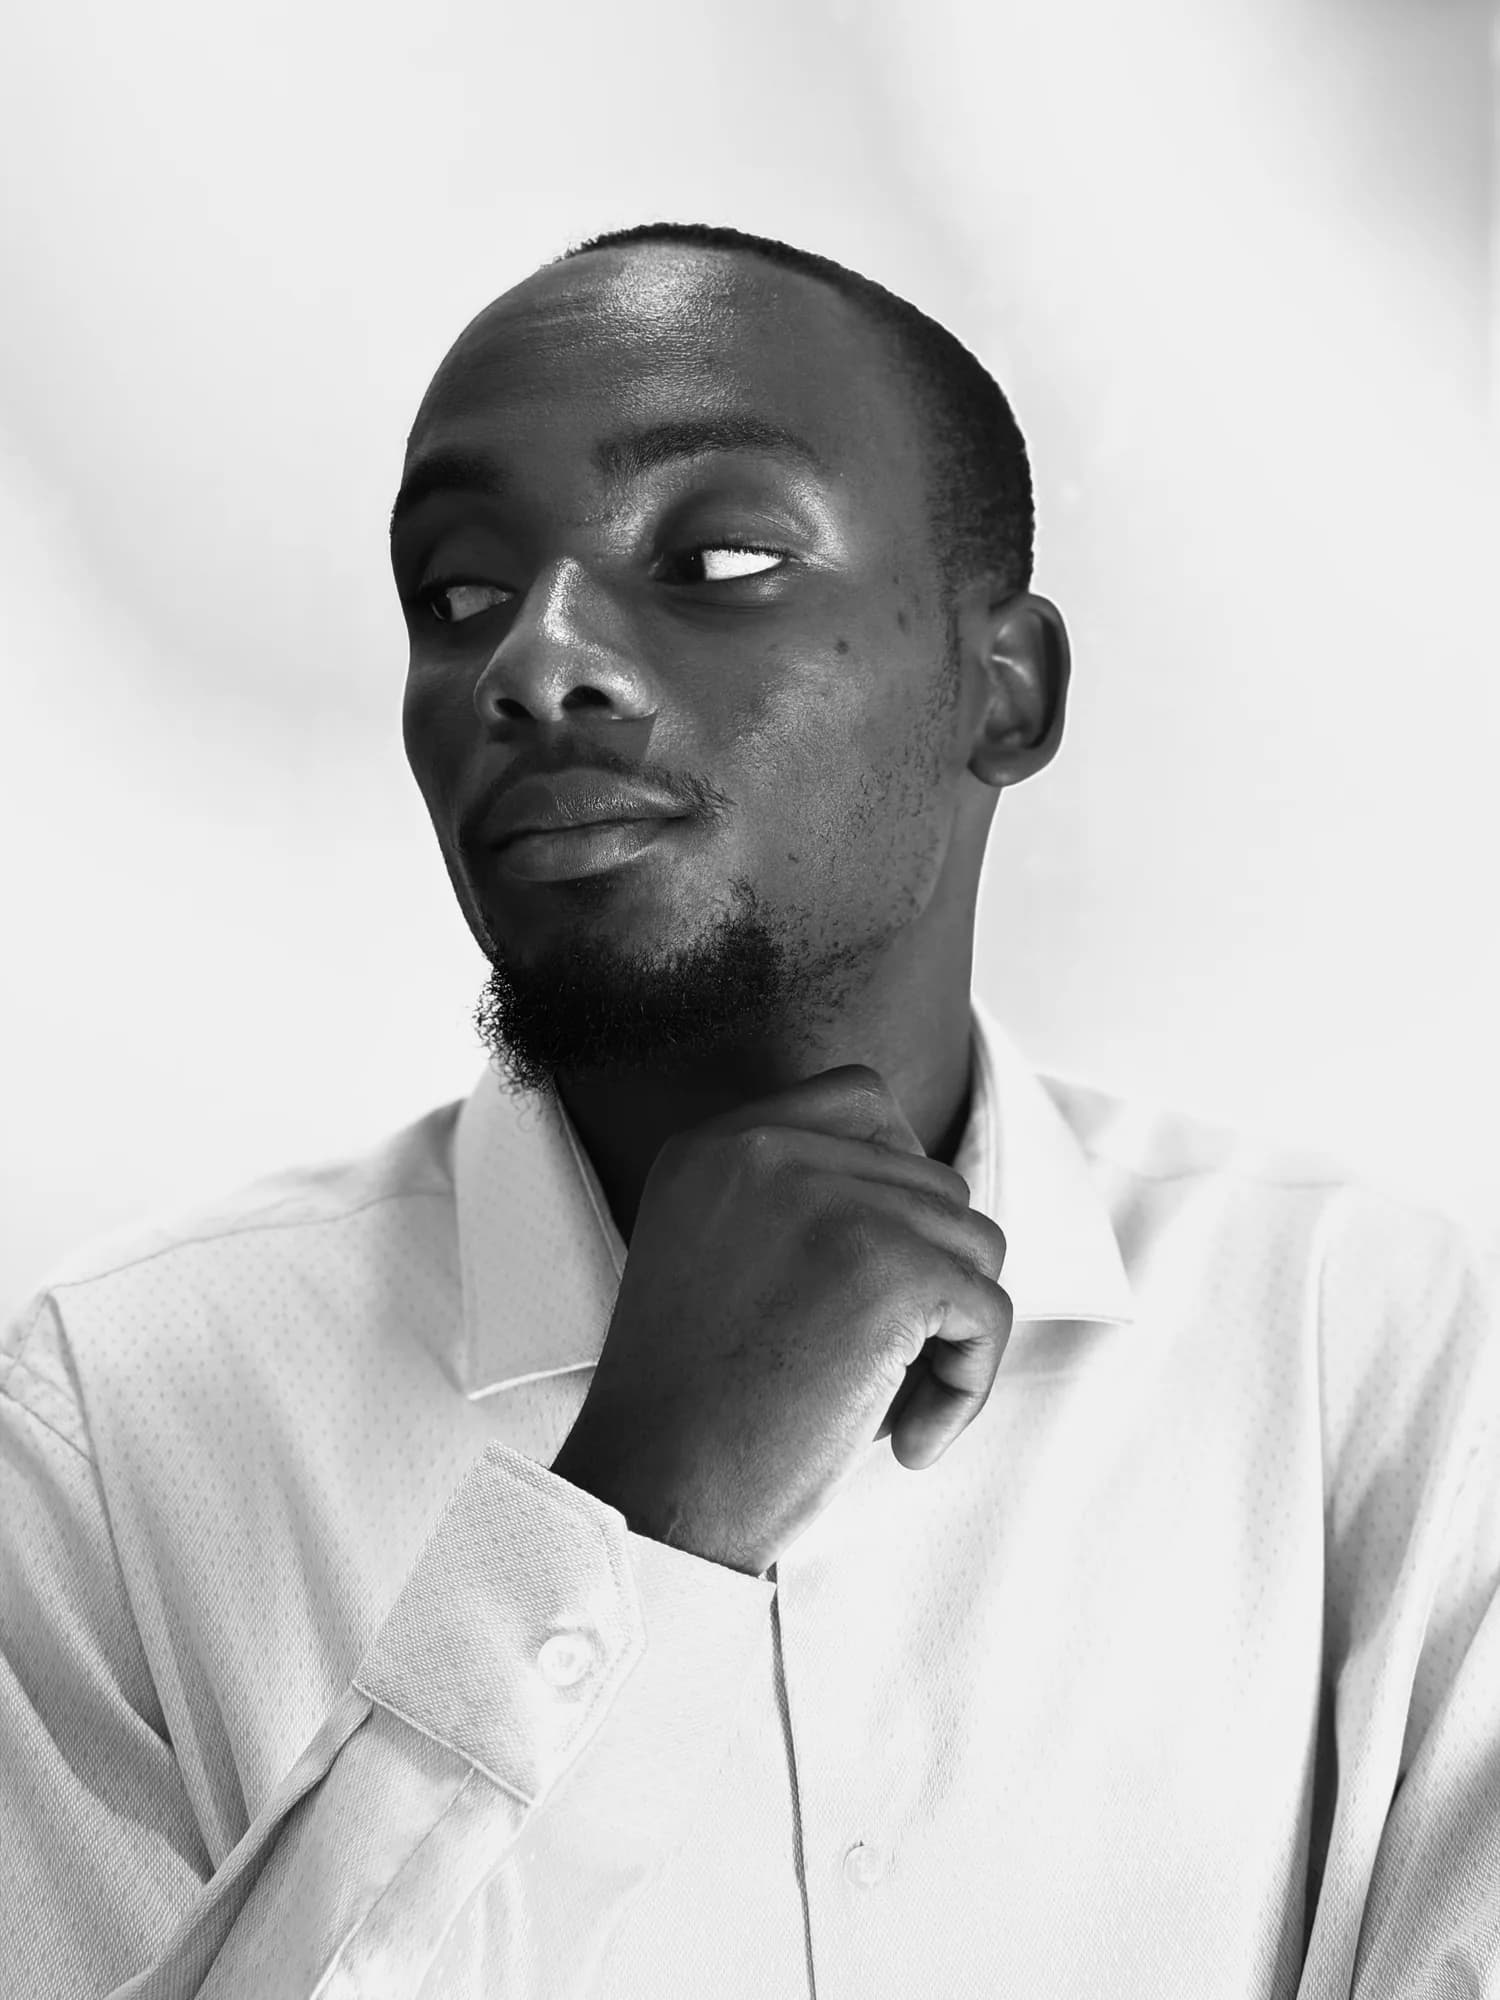
Hello, I'm Khalifa.
I design and build complete machines, from the CAD model and circuit board to the firmware, the app and the field installation. My hardware runs on fish farms, in community eye screenings and on perimeter security towers, and I'm now studying for an MSc in Robotics at the University of Manchester.
Where it started
I wanted to be an inventor before I knew the word engineer. That curiosity now has tools behind it, and every project gets me a little closer.
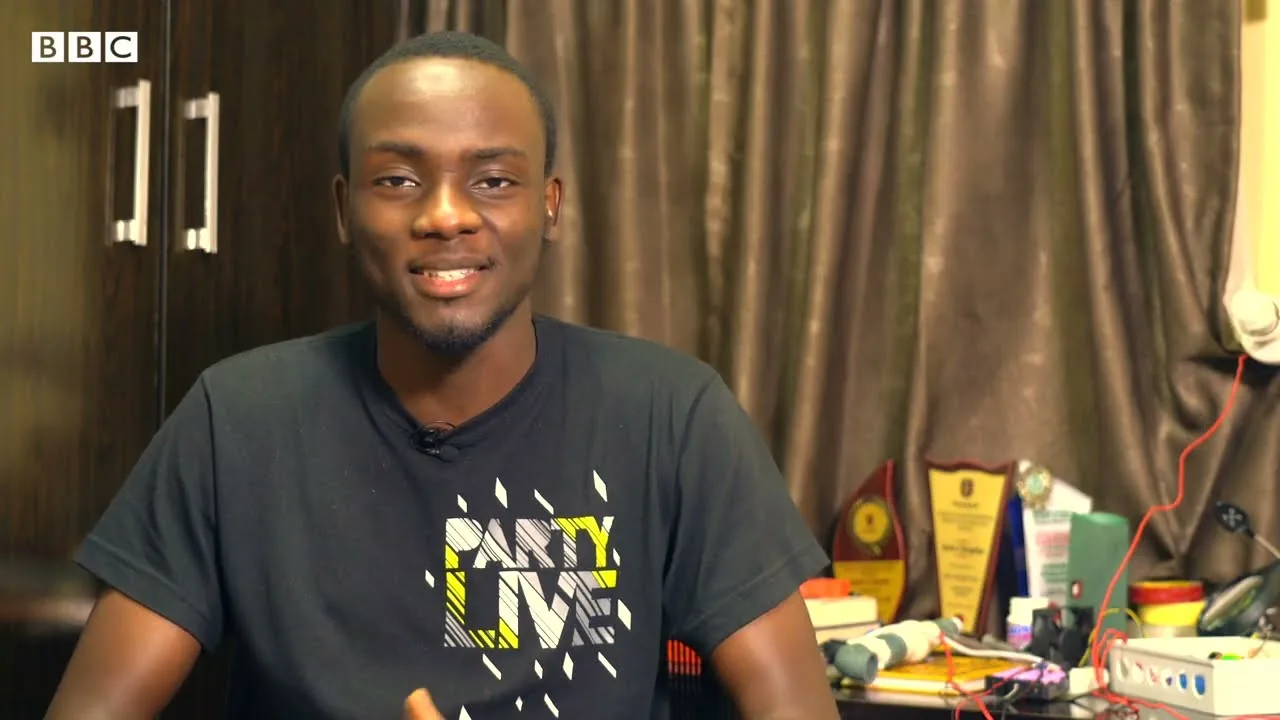
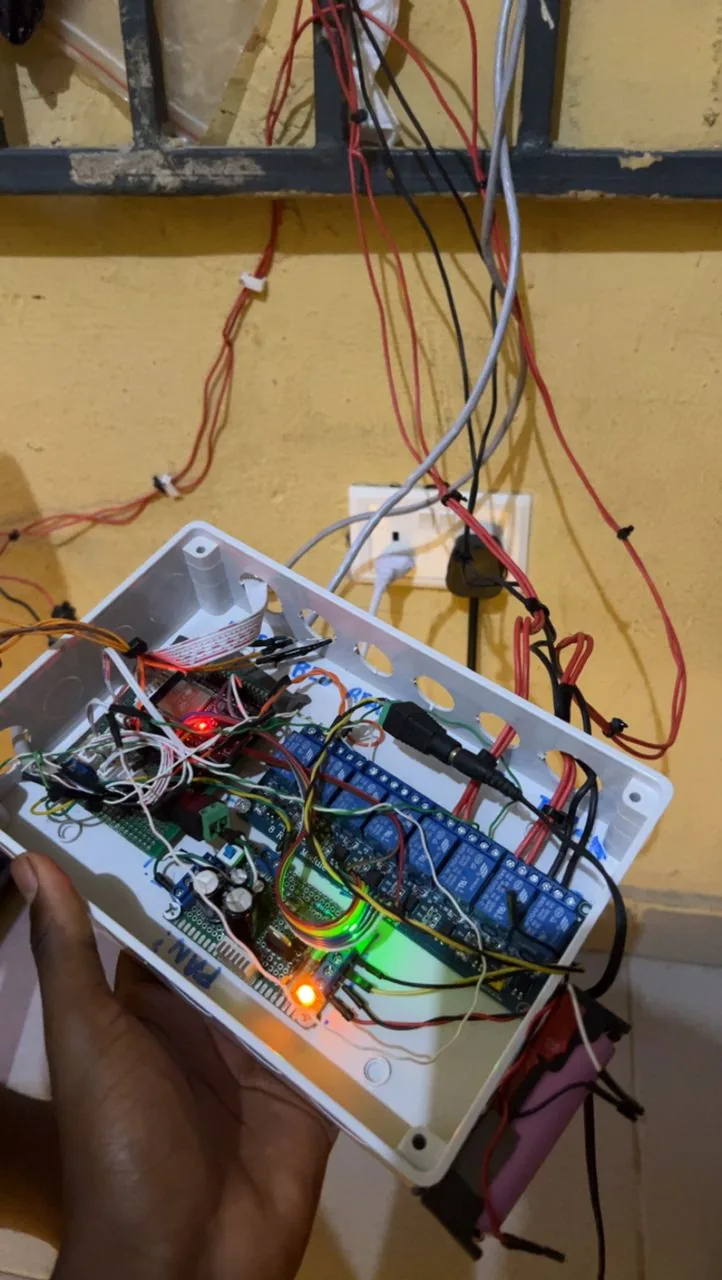
I studied Mechatronics Engineering at Afe Babalola University and graduated with First Class Honours. While I was there I turned my own room into a smart room, which BBC News Hausa later covered, and served as president of the engineering students' association.
Since then I've led hardware teams as CTO of FundusAI and Trykey, co-founded Future Fish, and built control systems for Terra Industries. Each of those meant owning a machine from the first sketch to the day someone else could run it. Now I'm going deeper into robotics with an MSc at Manchester.
How I work
Principles I build by.
- 01
Own the whole machine
Mechanical, electrical and software decisions affect each other. Holding all three lets me make trade-offs that a hand-off between teams would miss.
- 02
Design for the real environment
Unstable power, patchy connectivity, heat and dust. I design for where the machine will actually live, and for what the people using it can afford.
- 03
Measure, don't guess
Controlled experiments, system identification and field data decide what changes. Opinions are a starting point, not a result.
- 04
Finish properly
A project is done when someone else can run it without me: calibrated, documented and handed over.
01
Concept
Start from the problem in the field, not the parts list. Who is it for, what breaks today, what does success measure?
02
System design
Architecture across mechanics, electronics and software, so every subsystem is designed against the same constraints.
03
Build
CAD, PCBs, firmware, apps and fabrication. I make the parts myself, so I know exactly where the tolerances live.
04
Test & deploy
Verified against the requirements, trialled in the field and documented, with data to prove it works and people trained to run it.
Skills & tools
- 01
Robotics & control
Manipulators, mobile platforms and the maths that moves them.
- ROS 2
- MATLAB
- Python
MethodsKinematics · Motion control · System identification · Control systems
Proven inARCTOS six-axis robot arm, Rocker-bogie rover
- 02
Embedded systems
Firmware and electronics that survive outside the lab.
- C
- C++
- Arduino
- ESP32
- STM32
- Raspberry Pi
- NVIDIA Jetson
- MQTT
- Altium Designer
- Embedded Linux
MethodsIoT architecture · OTA updates · Power switchover design
Proven inFuture Fish aquaculture automation, Kallon sentry tower, Rickshaw monitoring & yield modelling
- 03
Mechanical design & CAD
Parts designed to be made, and made by me.
- SOLIDWORKS
- AutoCAD
- FDM 3D printing
- CNC machining
- PCB etching
MethodsTolerance analysis · Motion studies & simulation · Mechanism design
Proven inLumina handheld ophthalmoscope, CubeSat structure & deployables, ARCTOS six-axis robot arm
- 04
Software & data
The dashboards, apps and models that make hardware useful.
- Python
- JavaScript
- pandas
- NumPy
- SQL
- Mobile apps
MethodsMachine learning · Real-time data pipelines · Linux services
Proven inFuture Fish aquaculture automation, Rickshaw monitoring & yield modelling
Career objective
I want to build robots that leave the lab and do real work: industrial manipulators, field robots and precision instruments. I'm looking for a robotics or mechatronics role where I can own systems end to end, at a team that ships hardware.
Research interests
- 01Mechatronic system design and modelling
- 02Embedded control systems and robotics
- 03Intelligent agricultural systems
- 04Data-driven optimisation of engineering systems
- 05Low-cost precision instrumentation
- 06Cyber-physical systems and IoT architecture
Education
From a First in Mechatronics to an MSc in Robotics.
The University of Manchester
2026 – 2027MSc Robotics
- Funded by the PTDF Overseas Scholarship.
Afe Babalola University
Graduated Oct 2023BEng Mechatronics Engineering · First Class Honours
- CGPA 4.80 / 5.00.
- Final project: a quadcopter for aerial irrigation and herbicide spraying with a feedback mechanism.
- Coursework included robotics and automation, electromechanical systems, digital systems and PLCs, and control systems.
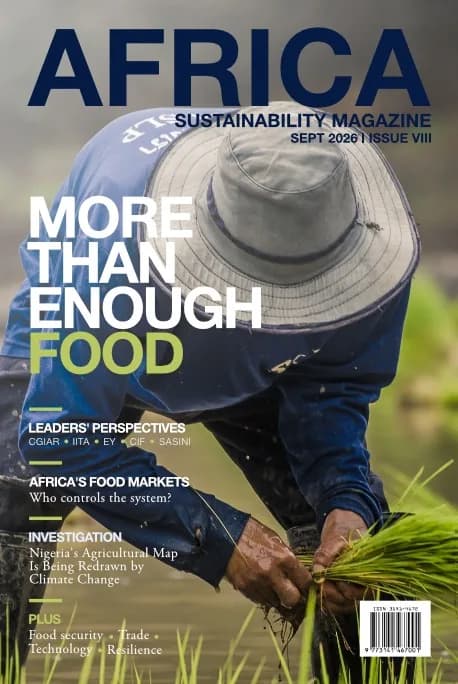
In the press
Extra! Extra!
Read all about it.